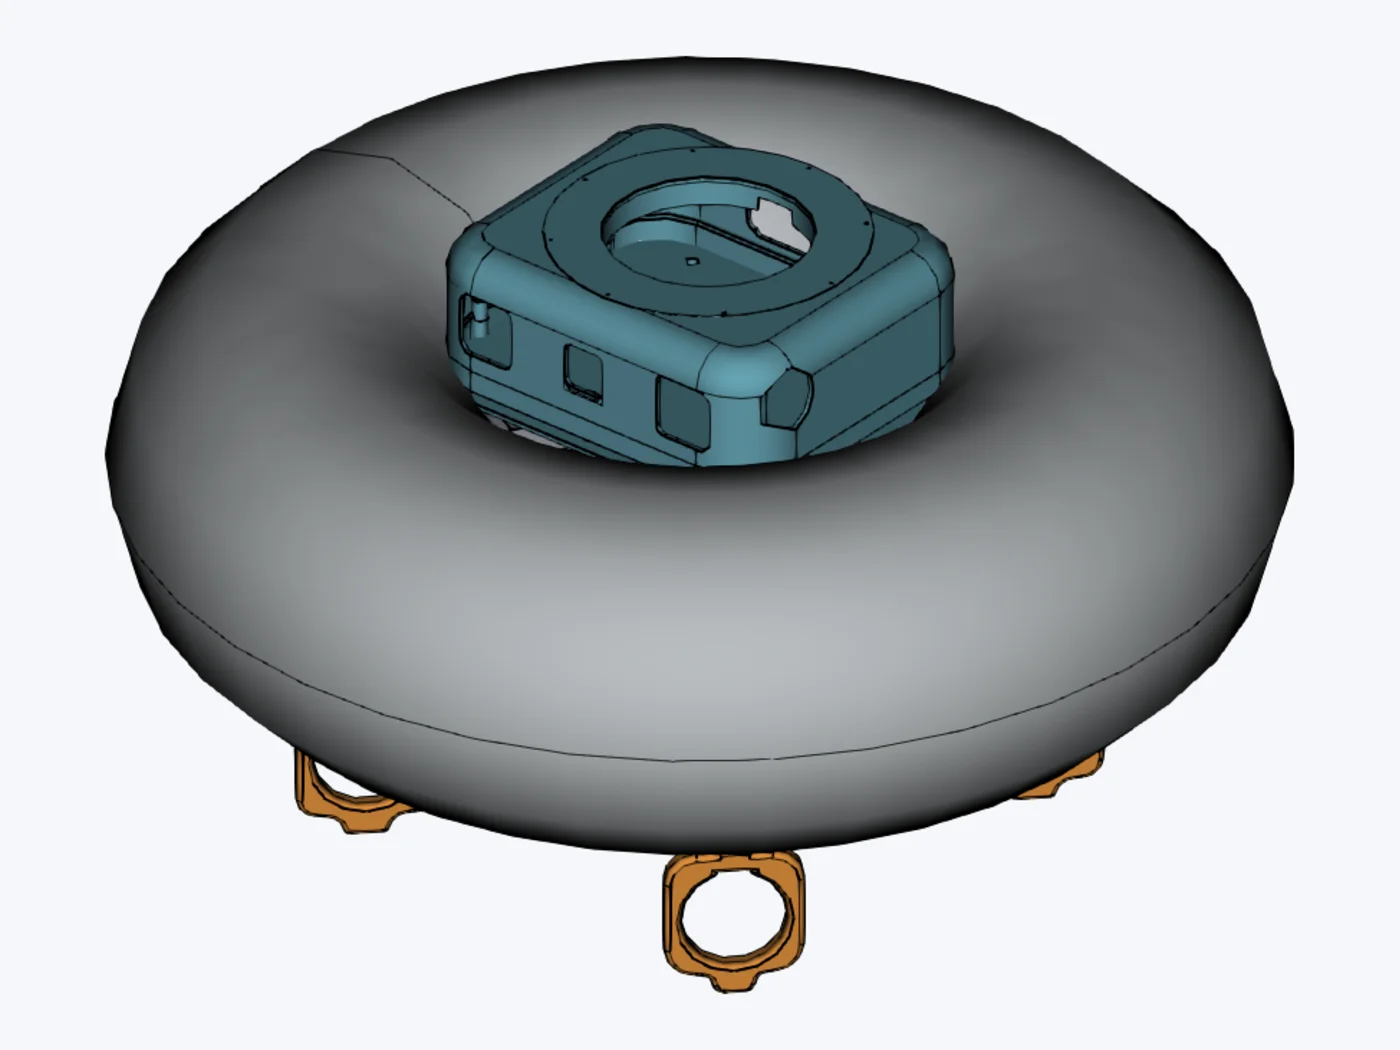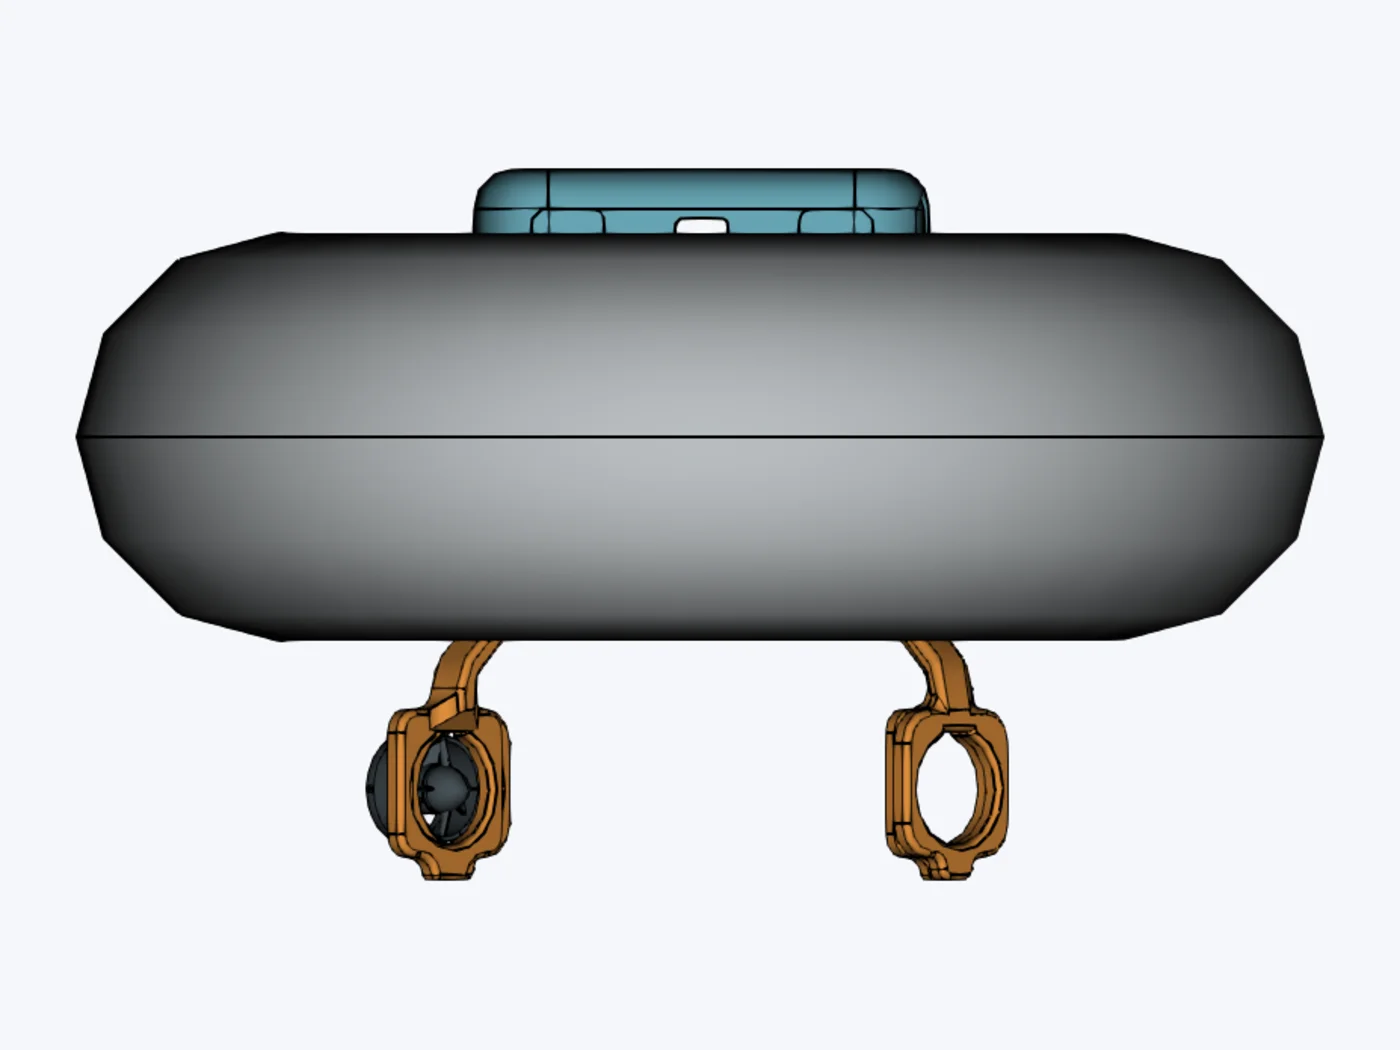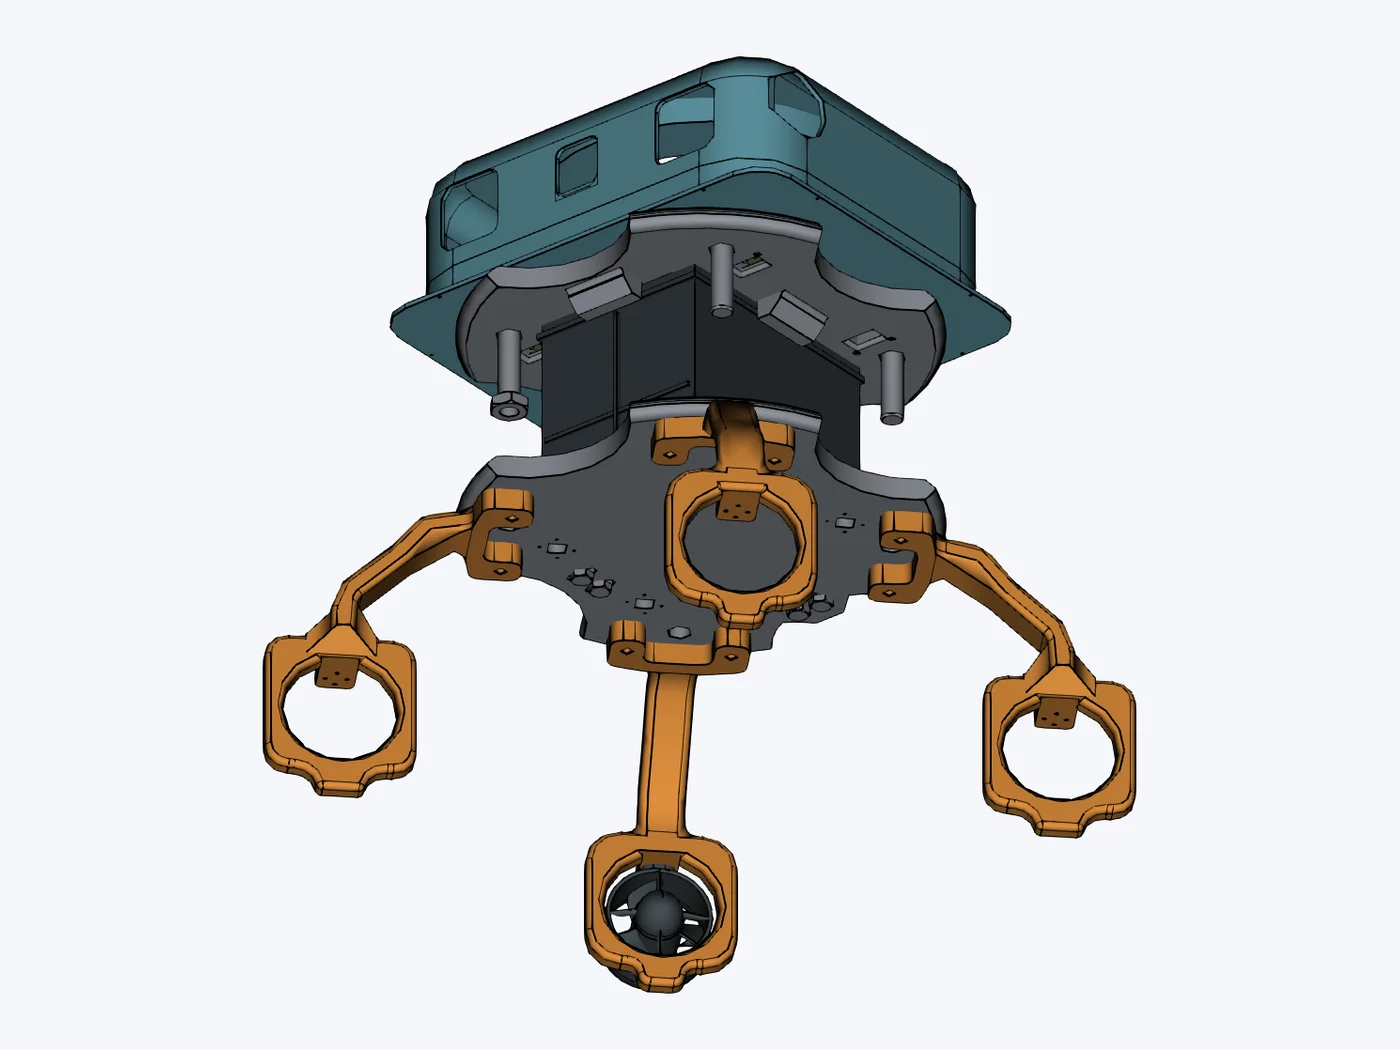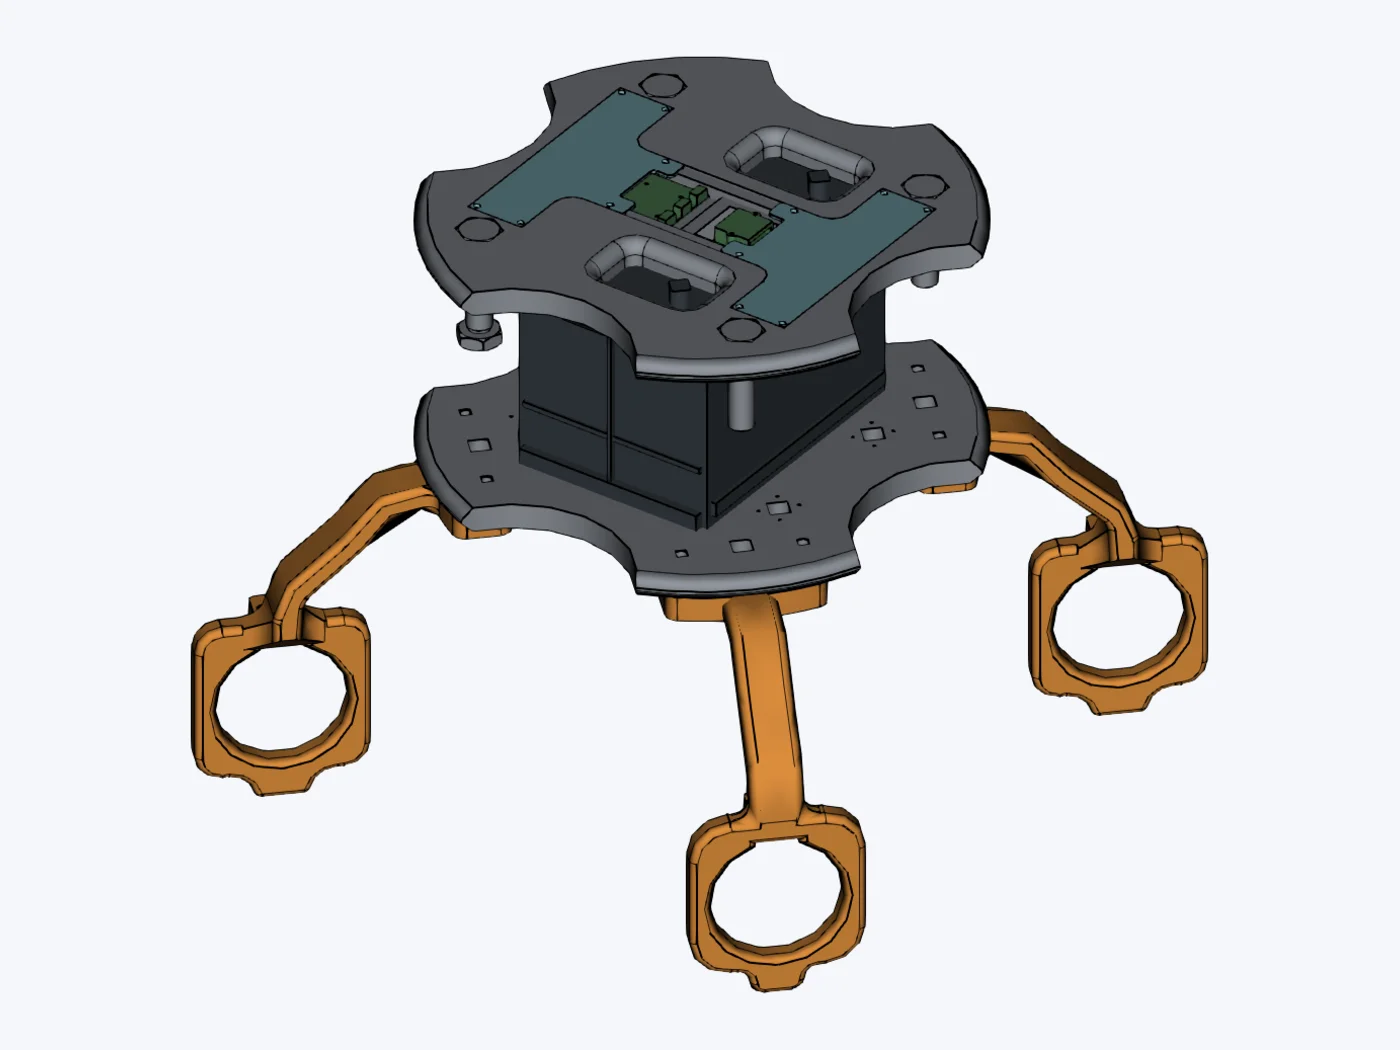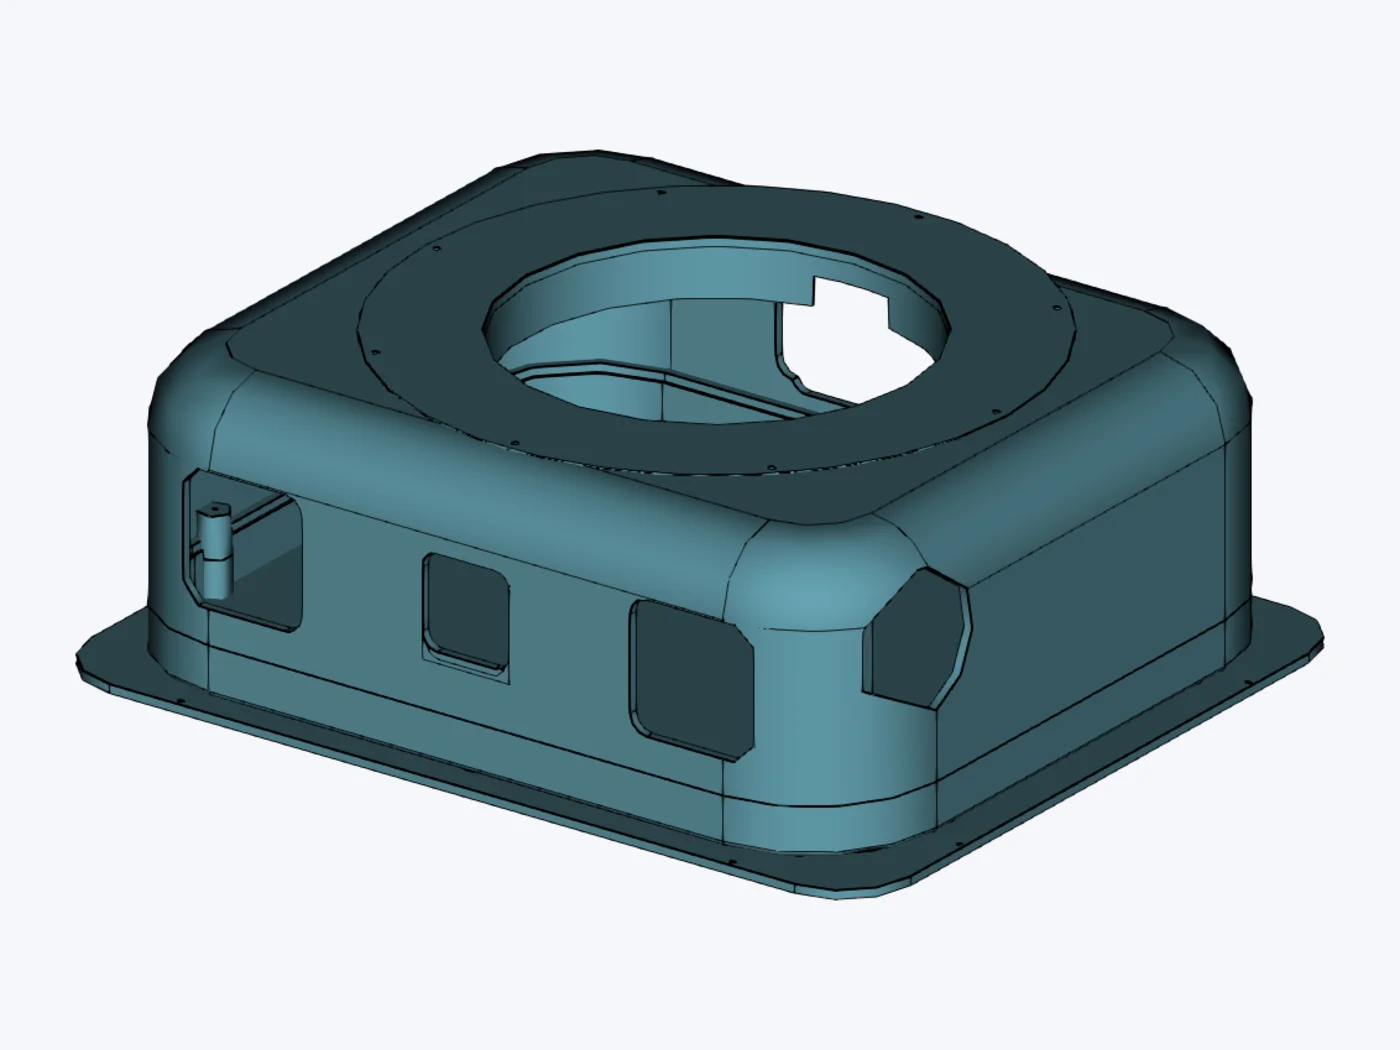
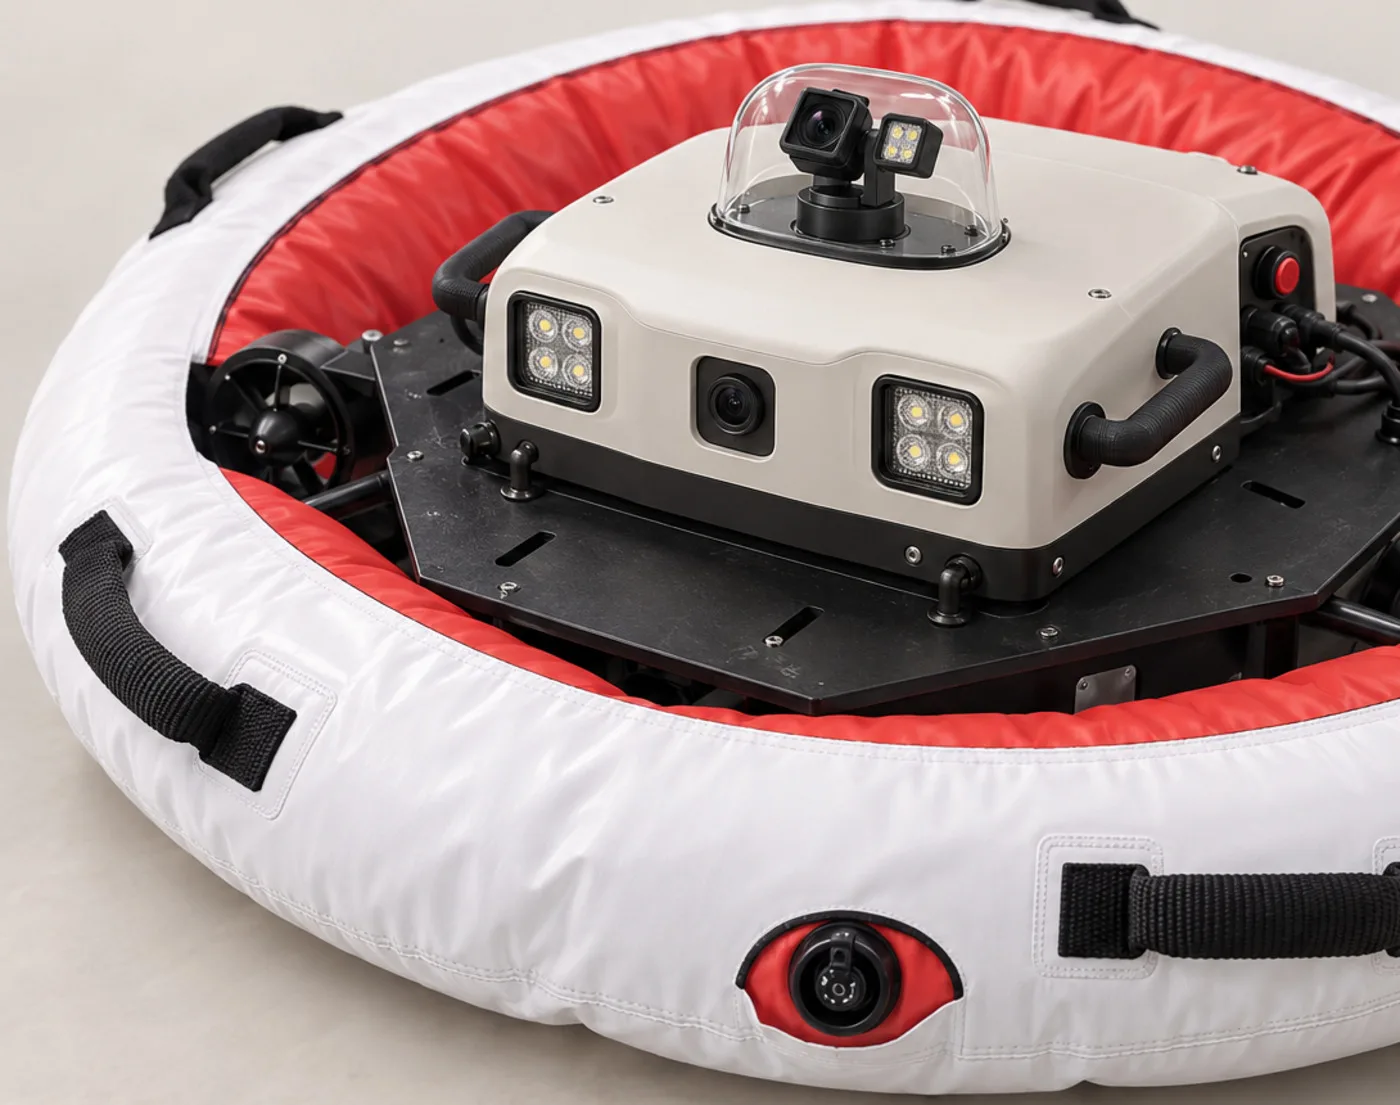
FLOAT-E is a small robot boat for inspecting the underside of docks and jetties. An operator drives it under the structure, a camera in the dome looks up, and every photo is filed by where it was taken. An hour under a jetty comes back as an inspection report, not an hour of unsorted video.
It’s our first robot built for a real port, and it’s being built in one, at The Vessel in the Port of Antwerp-Bruges.
Why we’re building it
Ports are full of structure that’s hard to reach: quays, jetties and pillars that need regular checks, mostly from below the deck and close to the water. Today that’s slow, wet work. A small, cheap robot that a person can drive under a jetty and that sorts the footage on its own could make those checks faster and safer.
FLOAT-E started as a security demo for spotting drones over the water. In September we changed direction after talking to people in the port, because inspection is the problem they actually have.
Where it’s going
FLOAT-E works on the bench and in simulation. Next comes a sealed enclosure, the first tests in the water, and then the first runs under a real jetty. After that it needs to find its way where GPS doesn’t reach, and a sharper camera for spotting small cracks.
If you know marine robotics or inspection work, come by the Open Lab at The Vessel or write to [email protected].